PhD Candidate · Robotics Software Engineering

Building adaptive robotic systems for a changing world.

I study how robots and their digital counterparts can remain effective when missions, environments, and design-time assumptions change.

GSSI L'Aquila, Italy
2023—Now PhD in Computer Science
Focus Adaptive robotics
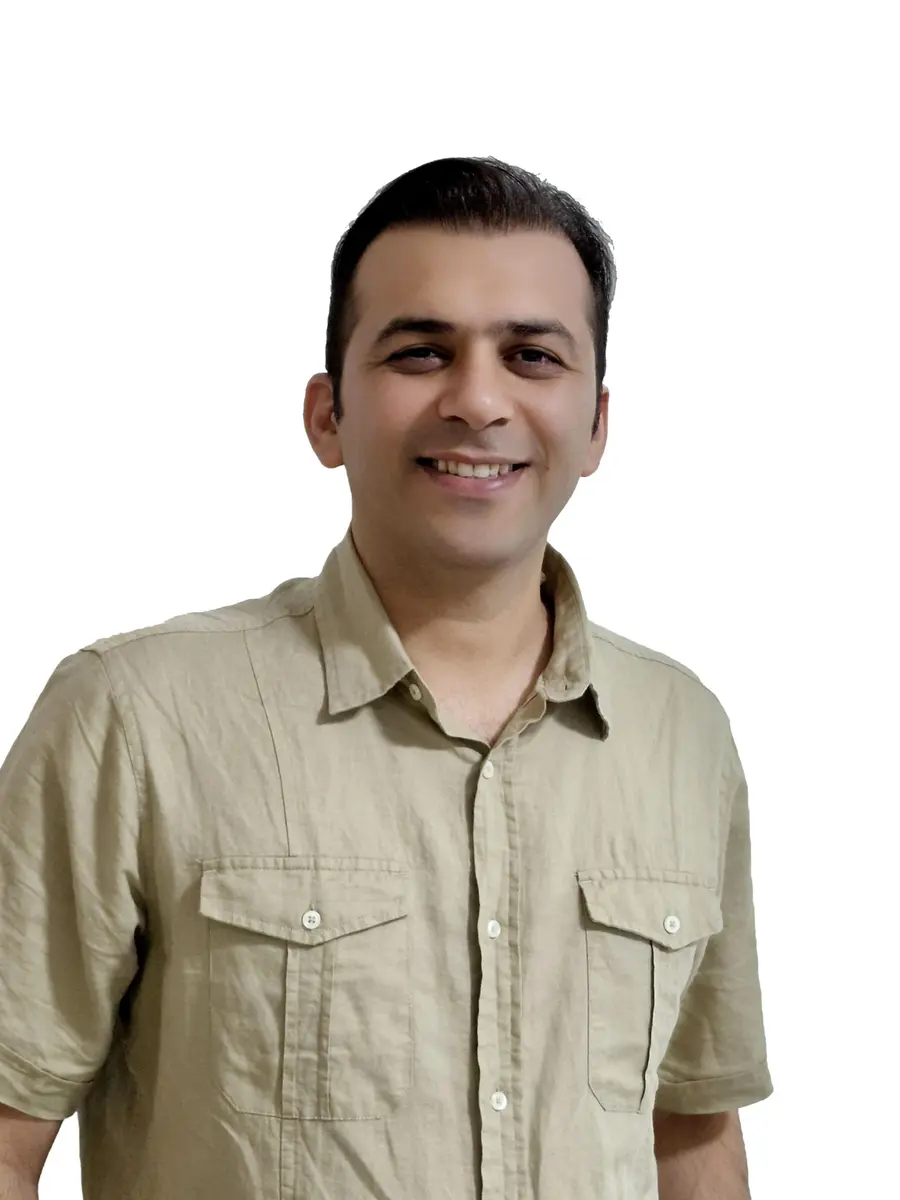
Portrait of Mehran Rostamnia
Researching at Gran Sasso Science Institute
Behavior Trees
Digital Twins
Self-adaptation
Scroll to explore

01 · About

Software engineering for robots that must outlive their assumptions.

I am a PhD candidate in Computer Science at the Gran Sasso Science Institute, working at the intersection of robotics and software engineering.

My research asks a practical question: how can long-living robots keep their behavior, knowledge, and digital representations aligned as the world changes? I investigate adaptive behavior architectures—especially Behavior Trees—and evolving Digital Twins, with an emphasis on uncertainty, runtime change, traceability, and assurance.

I work with Prof. Patrizio Pelliccione and collaborate with researchers across robotics and software engineering.

Robotics Behavior Trees Digital Twins Self-Adaptive Systems Mission Specification

02 · Research

Three connected research directions.

From runtime behavior to system-level evolution.

01

Adaptive robot behavior

Understanding when classical Behavior Trees are sufficient, where they reach their boundary, and how generation, extension, evolution, and refinement mechanisms can help.

  • Behavior Trees
  • Runtime adaptation
  • Uncertainty
03

Engineering autonomy

Applying software architecture, requirements engineering, and self-adaptive-systems principles to make autonomous robots understandable, resilient, and safe to evolve.

  • Architecture
  • Mission specification
  • Assurance

A recurring research question

Where should adaptation live?

  1. 1DetectWhat changed?
  2. 2DecideWho responds?
  3. 3ChangeWhat may evolve?
  4. 4AssureWhat evidence is enough?

Current work

Adaptation Needs in Robotic Systems

A study assessing what robotic adaptation requires, where classical Behavior Trees help or fall short, and how enhanced BT approaches address the remaining needs.

6 adaptation-need families 4 BT technique families Literature + practitioner evidence

03 · Publications

Selected publications.

View Google Scholar
2026 Journal article

Digital Twin Models for Space Robotics: Objectives, Applications, and Challenges

Array · Elsevier

2025 Workshop paper

Towards Adaptable and Uncertainty-Aware Behavior Trees

IEEE/ACM International Workshop on Robotics Software Engineering

2021 Journal article

An Efficient Path-Based Approach for Influence Maximization in Social Networks

Expert Systems with Applications · Elsevier

2019 Conference paper

Vertex Cover Preprocessing for Influence Maximization Algorithms

Conference on Knowledge Based Engineering and Innovation

04 · Journey

An academic path shaped by software, systems, and people.

  1. Nov 2023—Now

    Doctoral research

    PhD Candidate in Computer Science

    Gran Sasso Science Institute · L'Aquila, Italy

    Robotics software engineering, adaptive systems, Digital Twins, and mission specification.

  2. 2020—2022

    Professional experience

    Information & Communication Technology Teacher

    Ministry of Education · Iran

  3. 2019

    Education

    MSc in Computer Science

    Shahid Rajaee Teacher Training University

05 · Contact

Let’s discuss adaptive robotics.

I am always glad to exchange ideas about Behavior Trees, evolving Digital Twins, self-adaptive systems, and research collaborations.